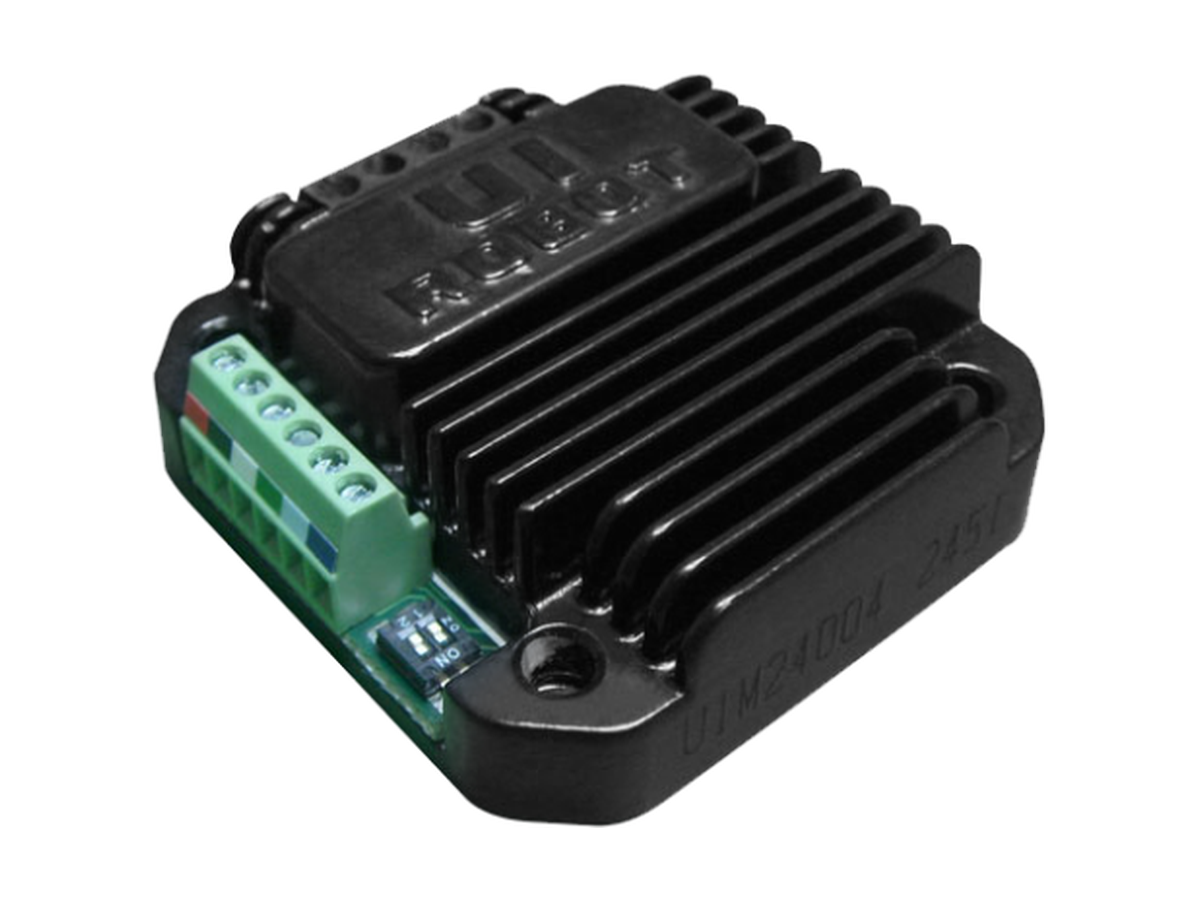
Pulse & speed control
UIM240
Step and direction input for integration with an external motion controller. Review the family reference and confirm the model for your motor and power supply.
Explore in Product Selector →UIRobot
Compact stepper drives with pulse, serial, CAN and speed-control interfaces. Explore the UIM families and let Mach help confirm the model for your motor and control system.
Explore UIRobot products
Step / direction / Serial / CAN / Speed control
About UIRobot
Explore UIRobot stepper drives through Mach Motion Products. Choose a family by how you want to control the motor. Electrical ratings and features vary by model; share your application so we can confirm the configuration.
Choose a product family below to explore selection details and product references in our Product Selector. Mach can help you work through the requirements for your application.
Pulse & speed control
Step and direction input for integration with an external motion controller. Review the family reference and confirm the model for your motor and power supply.
Explore in Product Selector →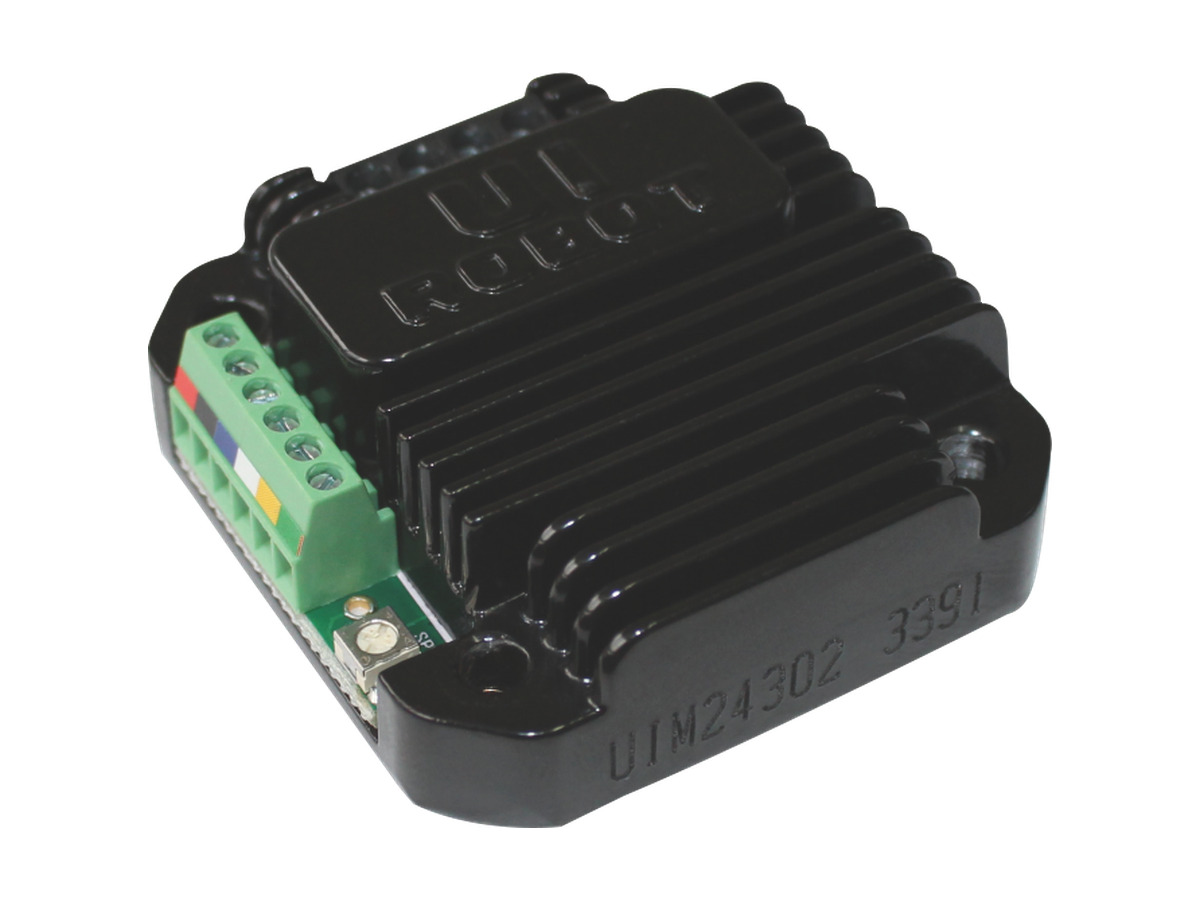
Pulse & speed control
Speed control is set with an onboard adjustment, external potentiometer or analog input, depending on model. Explore the options and confirm the control arrangement with Mach.
Explore in Product Selector →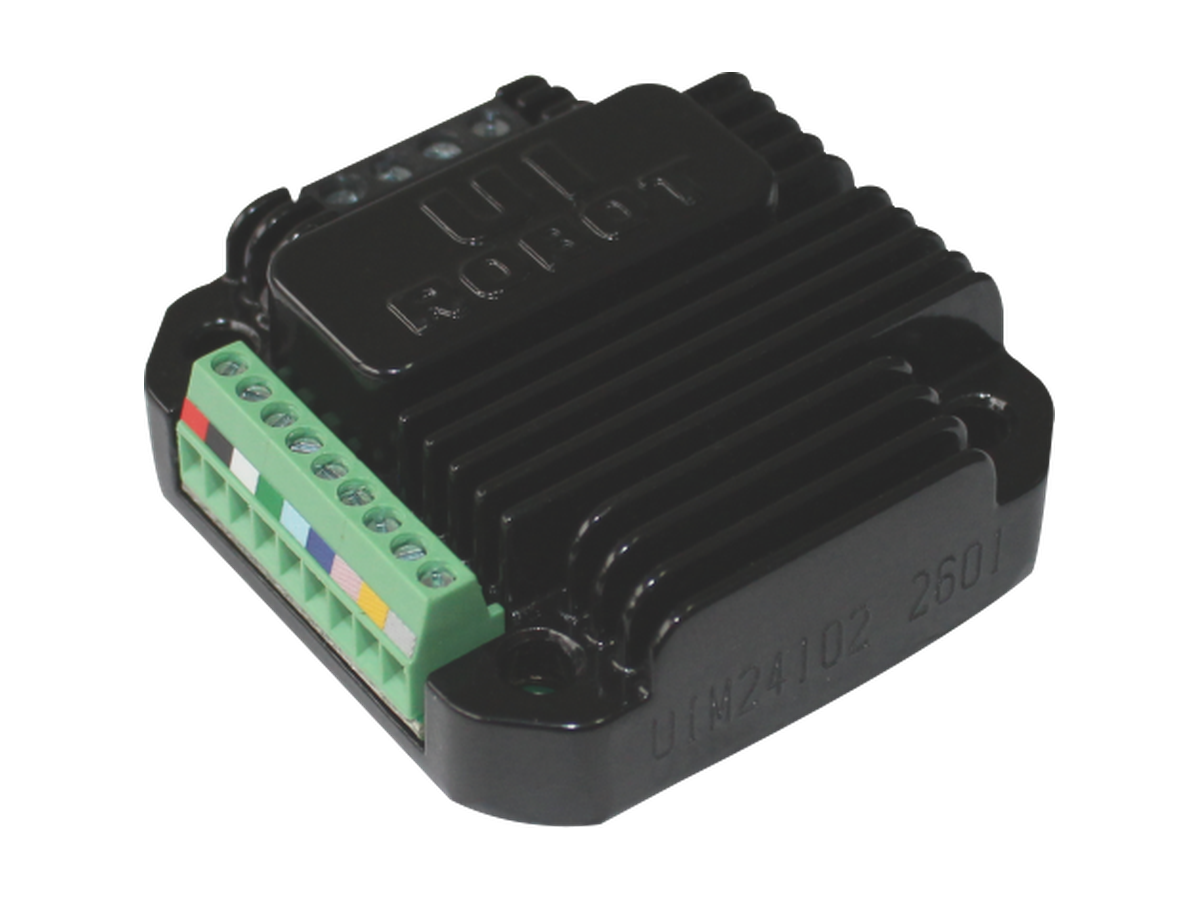
Serial & network control
RS232 commands provide serial control of stepper motion. Explore the family information and discuss the command interface and motor pairing with Mach.
Explore in Product Selector →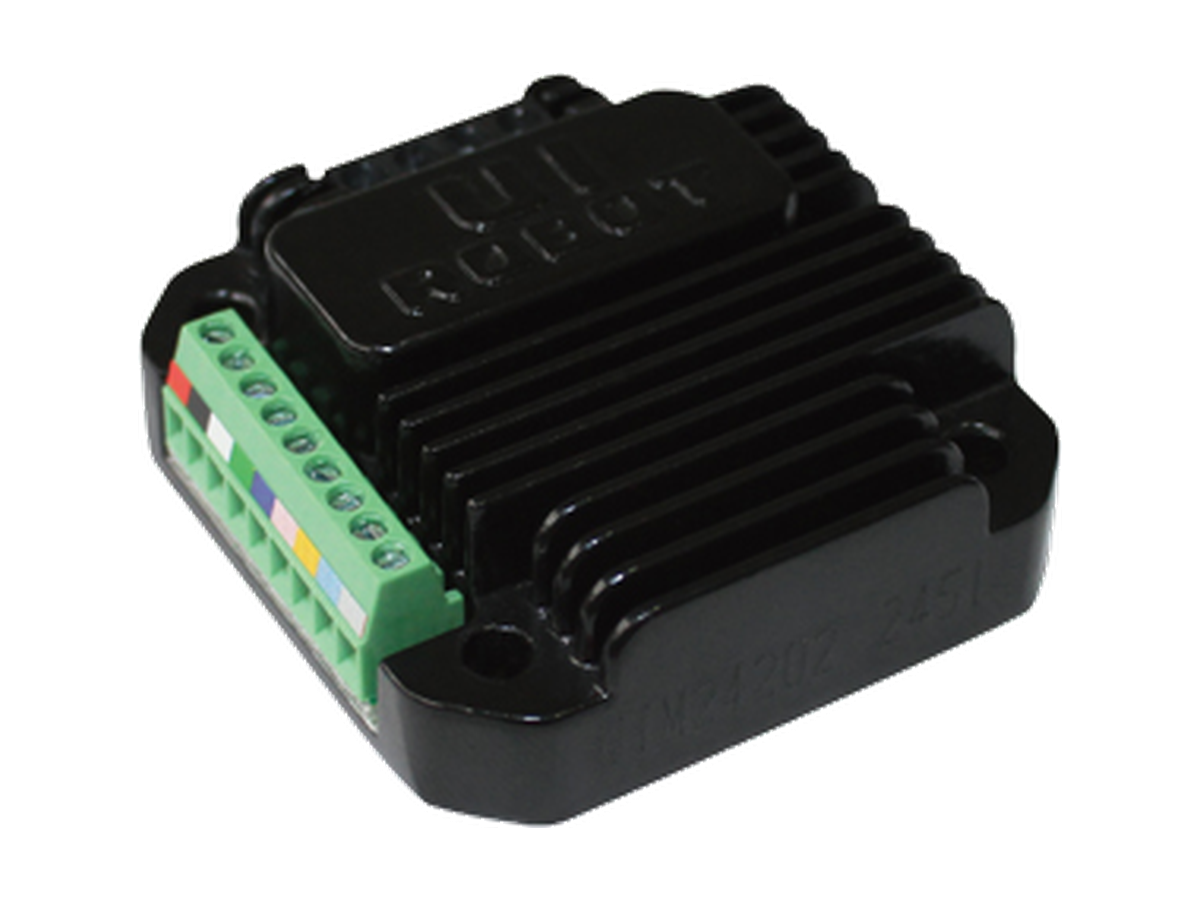
Serial & network control
CAN communication connects stepper controllers in a network. Review the family reference and discuss the gateway, motor and control requirements with Mach.
Explore in Product Selector →Application support
Share the motor model, phase current, supply voltage and preferred control interface. Tell us whether you need position or speed control, and include any feedback requirements.
Discuss your application